
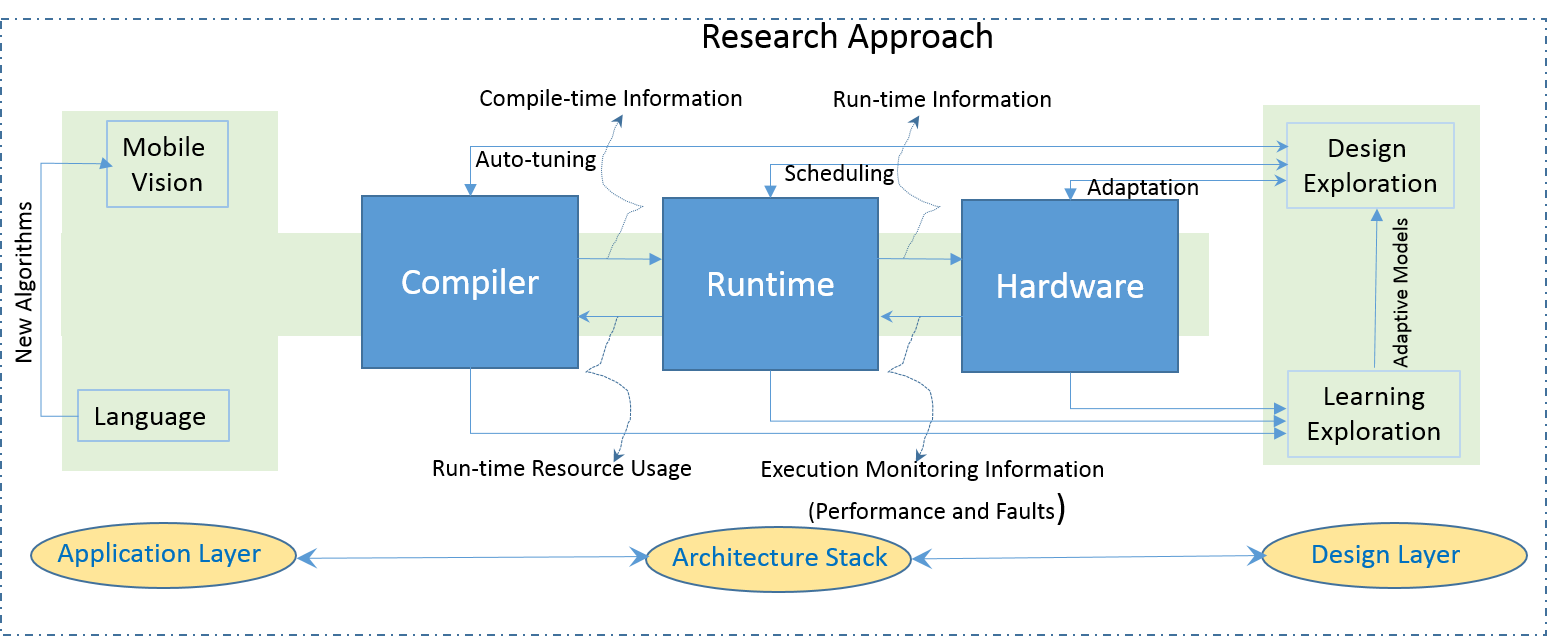
The main goal of this project is to research about algorithms and, architecture for a Reliable Many-core 3D-NoC System Targeted for Real-Time Vision Applications (i.e., gesture/motion/object recognition/surveillance). The system is based on our earlier developed reliable Network-on-Chip (OASIS). The system will integrate several dedicated PEs for ILP/Data/Thread level parallelism, while the 3D-OASIS NoC orchestrates communications between PEs and is used for large amount of data transactions among tasks.
June 2015: Team KAIST Wins DARPA Robotics Challenge
Labs


